


Imaginile produselor au caracter informativ si pot prezenta diferente minore, in functie de lot si de furnizor. Este posibil ca specificatiile si pretul produselor sa fie modificate fara preaviz. Facem tot posibilul sa adaugam in pagina produselor specificatii cat mai exacte si corecte dar este posibil ca acestea sa nu fie in totalitate corecte. in cazul in care identificati un astfel de caz, va rugam sa ne semnalati acest lucru.
Produsul este destinat specialistilor si nu include instructiuni de asamblare/utilizare. Produsul beneficiaza de garantia legala de conformitate (produsul este conform specificatiilor din site) egala cu durata de functionare medie a produsului de 14 zile de la data primirii produsului si de garantia Dead on Arrival (nefunctional la primire).
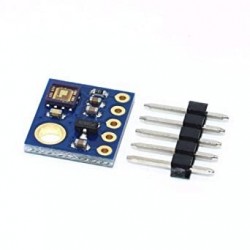
IR Infrared Slotted Optical Speed Measuring Sensor Detection Optocoupler Module For Motor Test
Specificatii:
1. + 5
+ 5 the positive input port for the power supply, can be connected to 3.3 V ~ 5 V voltage
2. The GND
GND for power negative input port
3. The OUT
OUT for the signal output, link MCU I/O port, general external interrupt
Note: the for arduino players should set the MCU I/O ports for the input mode/receiving mode, otherwise unable to use.
Other MCU, or more advanced control panel, such as Arm these, if need to set the I/O port as the input and output model, must be
Set to input mode/receive, otherwise unable to use.
51 series microcontroller can directly use, do not need to set the input and output model.
Program design.
Speed measuring module OUT link in the MCU external fracture, whenever there is a infrared ray conduction is an external buffer.
Logic design.
Measuring range:
Speed sensor output pulse signal, a pulse interrupt once;Infrared ray conduction time is low level, so we set the interrupt to be low
Touch the law level pattern.General integer grid encoder, whether it is a principle of how many, in fact, such as 10 grid encoder, there are ten empty
Grid, after one revolution of the motor is ray conduction 10 times, external touch low level 10 times;
Install the ideas above, we can play the effect of speed sensor, we know that 10 interrupt a circle, so we calculation
Number and the total number of except at 10 number of rotation of the motor, and then according to the perimeter of the wheel, calculate how long the wheel is a circle, you can
In order to determine the car has run far.
Measuring speed:
According to the thinking of the distance measurement, we use a MCU timer, 1 seconds to receive how many external interrupt, for example, a second received 20
External interrupt, we can judge the car speed for 1 second car wheels turn two laps, and then calculate the perimeter of the car wheels, can be learned
The speed of the car for 1 second.


feedback Report comment